RailCore® Labs
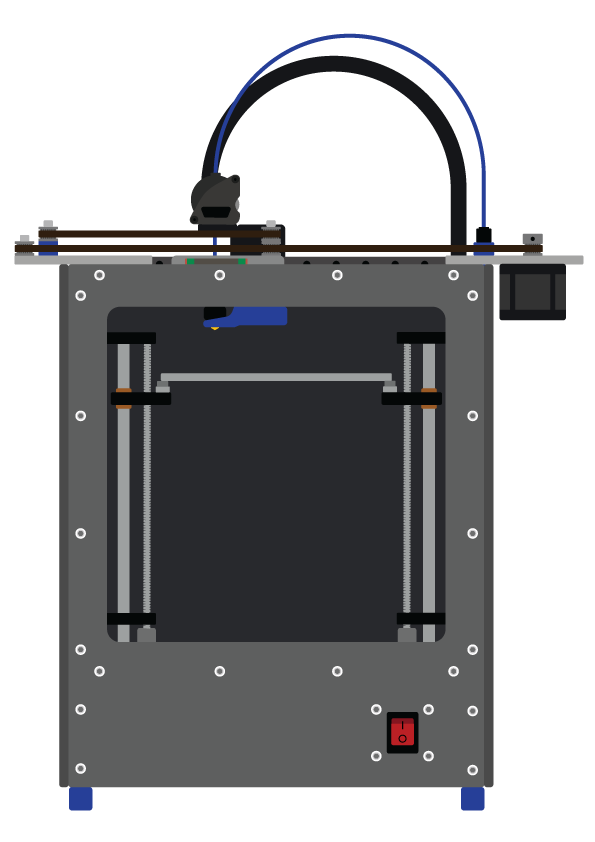
RailCore® is a family of Core-XY based Reprap 3D printers designed by J. Steve White, Tony Akens, and Ben Withem.
Klipper on a RailCore
The RailCore kits ship with Duet boards running RepRapFirmware (RRF), and the official configs are for RRF. Plenty of RailCore owners now run Klipper instead. This section covers what changes, which boards work, and how to set a RailCore up.
- RailCore Klipper config guide: kinematics, three-motor
z_tilt, probe, mesh, homing, input shaping and macros, step by step. - Sample configs in the
railcore/configs repo: RailCore II 300ZL/ZLT on the kit Duet 2 + Duex 5, and the RailCore Mini
on the kit Duet 3 Mini 5+. Starting points: every value marked
CHECK:must be verified on your machine.
Should you switch?
RRF on a Duet is a complete, well-supported setup. Nothing about the RailCore requires Klipper. Switch if you want one of these:
- Input shaping with a measured result. Klipper measures your printer’s resonances with an accelerometer and suggests the shaper for you. (RRF 3.4 and later has input shaping too; Klipper’s is the more widely used and documented.)
- The Klipper ecosystem: Mainsail or Fluidd, Moonraker, KlipperScreen, adaptive bed meshing,
exclude_object, and a large pool of community macros. - A cheaper or newer board. Klipper runs on most 32-bit boards, so a RailCore with a failed or missing Duet does not need another Duet.
- Config as text with macros. Klipper’s macros (Jinja2 templates) are easy to share and copy between printers.
Stay on RRF if your printer prints well and you don’t want a second computer in the loop, or if you rely on Duet Web Control, a PanelDue, or RRF features such as its standalone (no host) operation.
What changes compared to RRF
| RepRapFirmware (Duet) | Klipper | |
|---|---|---|
| Where motion is planned | on the Duet | on a host computer (usually a Raspberry Pi); the board only steps motors and reads sensors |
| Config | config.g plus homex.g, bed.g and other macro files on the SD card |
one printer.cfg (plus [include] files) on the host |
| Changing config | edit, then M98 P"config.g" or reboot |
edit, then FIRMWARE_RESTART |
| Web interface | Duet Web Control | Mainsail or Fluidd (through Moonraker) |
| Display | PanelDue | KlipperScreen on an HDMI/DSI touchscreen; the PanelDue is not a standard Klipper display |
| Three-motor bed leveling | M671 leadscrew positions + G32 running bed.g |
[z_tilt] section + Z_TILT_ADJUST |
| Mesh | M557 + G29 |
[bed_mesh] + BED_MESH_CALIBRATE (optionally adaptive) |
| Steps | steps/mm (M92) |
rotation_distance (mm per motor turn) |
| Motor current | M906 in mA |
run_current in amps RMS |
| Probe offset | G31 X Y Z |
x_offset, y_offset, z_offset in [bltouch] or [probe] |
| Homing | homeall.g, homex.g … |
[stepper_*] endstop settings + [safe_z_home] or [homing_override] |
Klipper names the two CoreXY motors stepper_x and stepper_y, but they are the A and B belt
motors, not the axes. On the RailCore II kit the rear motor (Duet X port) is stepper_x and the
front motor (Duet Y port) is stepper_y.
Boards
Duet 2 WiFi / Ethernet + Duex 5 (RailCore II kit)
Klipper supports the Duet 2 (SAM4E8E processor); start from Klipper’s generic-duet2-duex.cfg, or from our 300ZL sample, which already has the RailCore wiring. Know the limits first:
- Klipper talks to the Duet over USB. The WiFi or Ethernet module is not used, and there is no SPI link: the Duet 3 “SBC” SPI connection is an RRF feature and the Duet 2 does not have it. Mount the host computer in the electronics bay and run a short, good USB cable.
- USB back-powers the Duet. The Duet’s logic runs from USB, so it stays on when the PSU is off.
If Klipper starts while the motor power is off it can stop with a driver error; switch the
printer on, then send
FIRMWARE_RESTART. - TMC2660 drivers: Klipper drives them over SPI, but has no sensorless homing for them. Keep the endstop switches.
- Duex 5 endstop inputs cannot be used as endstops in Klipper (they go through an I/O expander). The kit only uses the Duet’s X and Y endstops and the Z probe input, so this does not matter for a stock build.
- Flashing wipes RRF. Back up your config first (Backup). Klipper is
flashed with
bossacafter erasing the board (Klipper’s Bootloaders guide, “SAM4 micro-controllers”). To go back to RRF, erase and flash the RRF firmware the same way.
Duet 3 Mini 5+ (RailCore Mini kit)
Klipper supports the Duet 3 Mini 5+ (SAME54 processor) and its Expansion Mini 2+ drivers; start from Klipper’s generic-duet3-mini.cfg or our Mini sample. The same USB-only and back-up-first notes apply. The Mini sample has had less real-world testing than the 300ZL one.
Replacement boards
Any board Klipper supports will run a RailCore. You need at least six stepper drivers (X, Y, three Z, extruder) and an input for the probe. Common choices:
- BigTreeTech Octopus or Octopus Pro, Manta M8P (8 drivers)
- BigTreeTech SKR 3 or SKR 2 (5 drivers: add a driver or a second board for the sixth motor)
- Fysetc Spider (8 drivers)
- A Duet 3 6HC (6 drivers)
Use the matching generic-*.cfg from
Klipper’s config folder for the pins, and
take the machine values (rotation distances, leadscrew positions, probe offsets) from our
sample configs.
What you need
- A host computer: a Raspberry Pi 3B+, 4 or 5 is typical; anything that runs Linux works.
- Klipper, Moonraker and Mainsail or Fluidd on it. KIAUH installs all of them.
- Optional but recommended: an ADXL345 accelerometer for input shaping.
Then follow the RailCore Klipper config guide.
Links
- Klipper documentation: Installation, Config Reference, Config checks
- Mainsail and Fluidd documentation
- Older community Klipper configs in railcore/configs
- Ask in the #help channel on the RailCore Discord: several members run Klipper RailCores.